Visual inspection: a robot that turns the part to the camera
A proof-of-concept inspection cell: a robot picks each part off the conveyor, presents every face to a fixed camera, and sorts it.
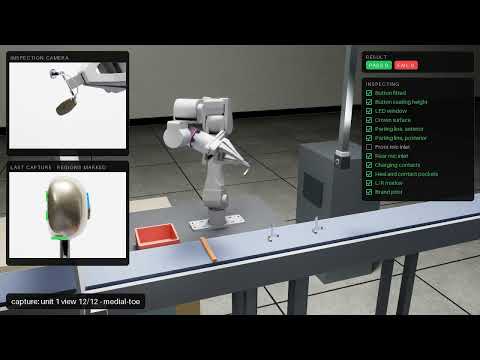
This is a POC demo for a prospective customer.
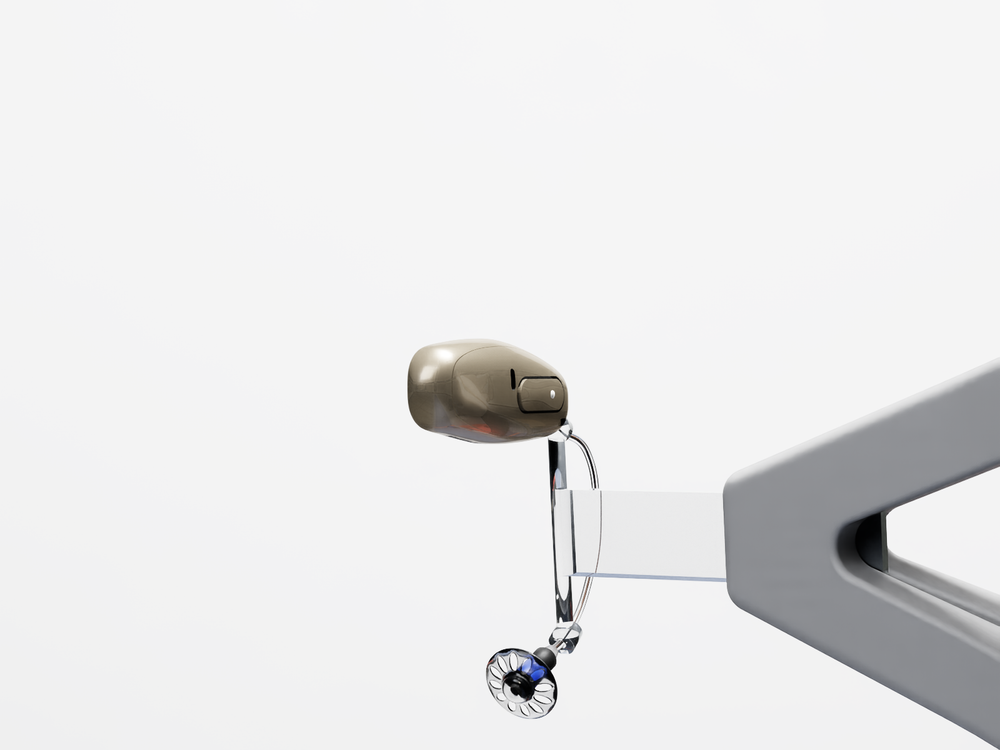
Here we've used the Phonak hearing aid as an example model.
In this example we've used a brace tab that holds the part by the joining cable and keeps the components at both ends rigid. This is likely not the ideal way to handle such a device. The target device for this customer demo is not a hearing aid at all — it's another object with similar size and quality assurance requirements. Due to NDAs, I'm not able to share any further details about it.
The simulation environment is, of course, NVIDIA Isaac Sim. The arm is an i2RT YAM, and the camera is modelled on the i2RT MF118. There is no detector in the cell yet: the pass/fail verdict in this run is scripted from each part's known state, while we are in discussions with a third-party model provider.